Question 10
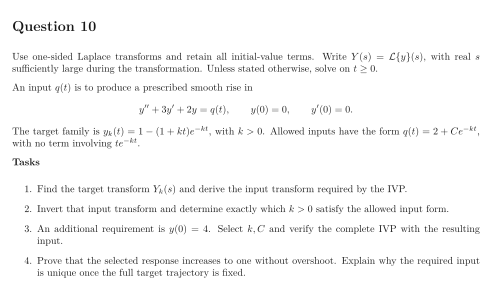
Use one-sided Laplace transforms and retain all initial-value terms. Write , with real sufficiently large during the transformation. Unless stated otherwise, solve on .
An input is to produce a prescribed smooth rise in The target family is , with . Allowed inputs have the form , with no term involving .
Tasks
Find the target transform and derive the input transform required by the IVP.
Invert that input transform and determine exactly which satisfy the allowed input form.
An additional requirement is . Select and verify the complete IVP with the resulting input.
Prove that the selected response increases to one without overshoot. Explain why the required input is unique once the full target trajectory is fixed.
Show solutionHide solution
Question 10 – Solution
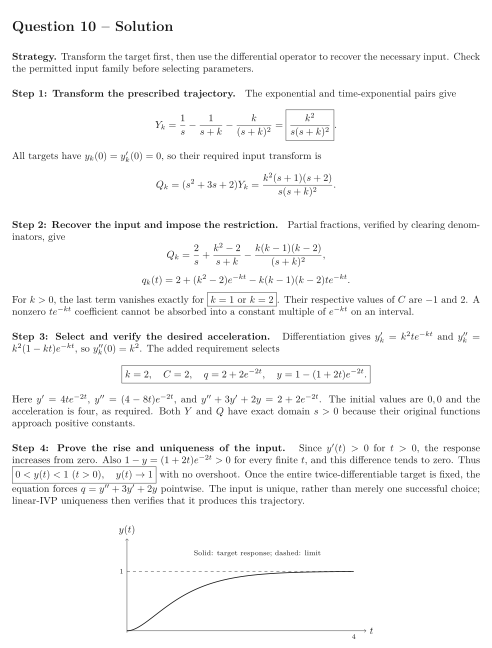
Strategy. Transform the target first, then use the differential operator to recover the necessary input. Check the permitted input family before selecting parameters.
Step 1: Transform the prescribed trajectory. The exponential and time-exponential pairs give All targets have , so their required input transform is
Step 2: Recover the input and impose the restriction. Partial fractions, verified by clearing denominators, give For , the last term vanishes exactly for . Their respective values of are and . A nonzero coefficient cannot be absorbed into a constant multiple of on an interval.
Step 3: Select and verify the desired acceleration. Differentiation gives and , so . The added requirement selects Here , , and . The initial values are and the acceleration is four, as required. Both and have exact domain because their original functions approach positive constants.
Step 4: Prove the rise and uniqueness of the input. Since for , the response increases from zero. Also for every finite , and this difference tends to zero. Thus with no overshoot. Once the entire twice-differentiable target is fixed, the equation forces pointwise. The input is unique, rather than merely one successful choice; linear-IVP uniqueness then verifies that it produces this trajectory.
See the diagram in the original worksheet below.