Question 4
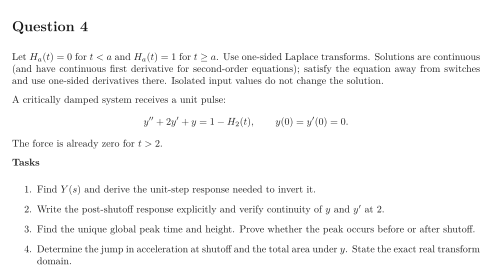
Let for and for . Use one-sided Laplace transforms. Solutions are continuous (and have continuous first derivative for second-order equations); satisfy the equation away from switches and use one-sided derivatives there. Isolated input values do not change the solution.
A critically damped system receives a unit pulse: The force is already zero for .
Tasks
Find and derive the unit-step response needed to invert it.
Write the post-shutoff response explicitly and verify continuity of and at .
Find the unique global peak time and height. Prove whether the peak occurs before or after shutoff.
Determine the jump in acceleration at shutoff and the total area under . State the exact real transform domain.
Show solutionHide solution
Question 4 – Solution
Strategy. A decaying stable system can continue moving upward after its input stops. Differentiate the actual tail to locate the peak.
Step 1: Transform the pulse. The zero data give Thus is the unit-step response, with and . The solution is .
Step 2: Simplify the tail and match. For , At this gives ; its derivative there is . Hence are continuous, with positive velocity even after the forcing is removed.
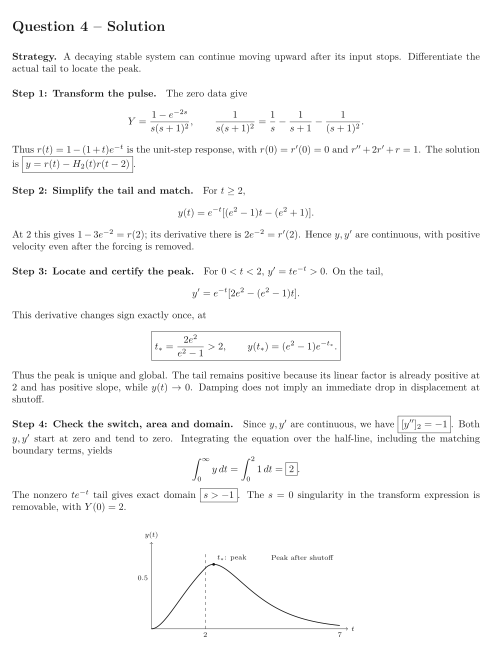
Step 3: Locate and certify the peak. For , . On the tail, This derivative changes sign exactly once, at Thus the peak is unique and global. The tail remains positive because its linear factor is already positive at and has positive slope, while . Damping does not imply an immediate drop in displacement at shutoff.
Step 4: Check the switch, area and domain. Since are continuous, we have . Both start at zero and tend to zero. Integrating the equation over the half-line, including the matching boundary terms, yields The nonzero tail gives exact domain . The singularity in the transform expression is removable, with .
See the diagram in the original worksheet below.