Question 9
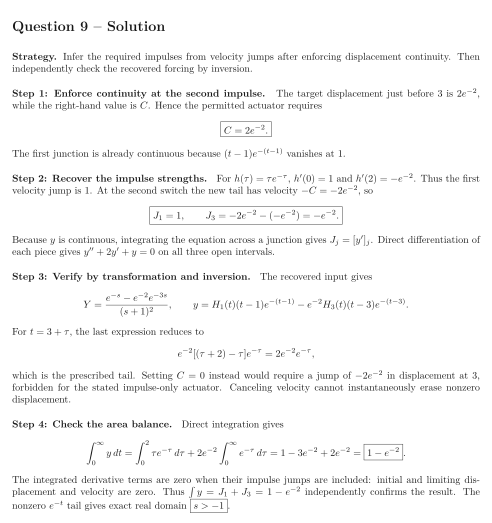
Use causal one-sided Laplace transforms. Write for and for . The unit impulse satisfies for continuous near . Interpret equations between impulses and through their jump conditions; use right-hand values at jumps. Write for a jump.
An actuator may use ordinary impulses at and , with no other force: The prescribed response has the form An ordinary impulse in this equation can jump velocity but not displacement.
Tasks
Determine the only possible value of under the permitted actuator.
Recover from the one-sided states, verifying that no ordinary forcing is needed between impulses.
Find , invert it, and confirm the prescribed tail. Decide whether choosing could shut the motion off instantaneously with an ordinary impulse.
Verify the total response area from the time formula and the integrated impulsive equation, and state the exact real transform domain.
Show solutionHide solution
Question 9 – Solution
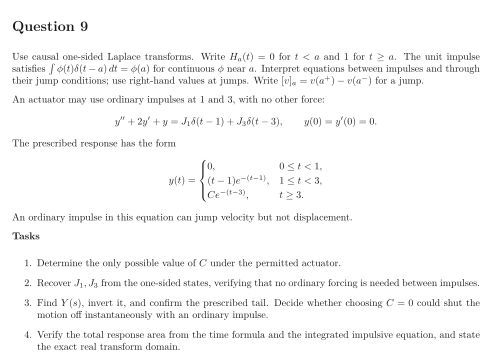
Strategy. Infer the required impulses from velocity jumps after enforcing displacement continuity. Then independently check the recovered forcing by inversion.
Step 1: Enforce continuity at the second impulse. The target displacement just before is , while the right-hand value is . Hence the permitted actuator requires The first junction is already continuous because vanishes at .
Step 2: Recover the impulse strengths. For , and . Thus the first velocity jump is . At the second switch the new tail has velocity , so Because is continuous, integrating the equation across a junction gives . Direct differentiation of each piece gives on all three open intervals.
Step 3: Verify by transformation and inversion. The recovered input gives For , the last expression reduces to which is the prescribed tail. Setting instead would require a jump of in displacement at , forbidden for the stated impulse-only actuator. Canceling velocity cannot instantaneously erase nonzero displacement.
Step 4: Check the area balance. Direct integration gives The integrated derivative terms are zero when their impulse jumps are included: initial and limiting displacement and velocity are zero. Thus independently confirms the result. The nonzero tail gives exact real domain .