Question 9
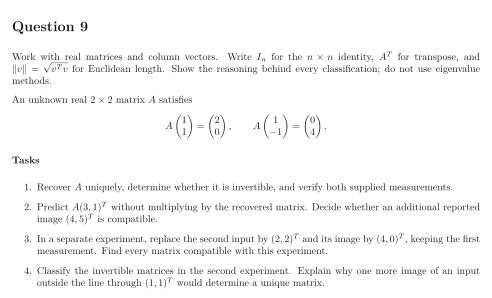
Work with real matrices and column vectors. Write for the identity, for transpose, and for Euclidean length. Show the reasoning behind every classification; do not use eigenvalue methods.
An unknown real matrix satisfies
Tasks
Recover uniquely, determine whether it is invertible, and verify both supplied measurements.
Predict without multiplying by the recovered matrix. Decide whether an additional reported image is compatible.
In a separate experiment, replace the second input by and its image by , keeping the first measurement. Find every matrix compatible with this experiment.
Classify the invertible matrices in the second experiment. Explain why one more image of an input outside the line through would determine a unique matrix.
Show solutionHide solution
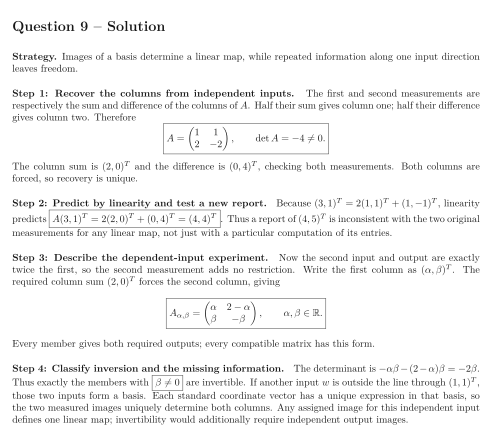
Question 9 – Solution
Strategy. Images of a basis determine a linear map, while repeated information along one input direction leaves freedom.
Step 1: Recover the columns from independent inputs. The first and second measurements are respectively the sum and difference of the columns of . Half their sum gives column one; half their difference gives column two. Therefore The column sum is and the difference is , checking both measurements. Both columns are forced, so recovery is unique.
Step 2: Predict by linearity and test a new report. Because , linearity predicts . Thus a report of is inconsistent with the two original measurements for any linear map, not just with a particular computation of its entries.
Step 3: Describe the dependent-input experiment. Now the second input and output are exactly twice the first, so the second measurement adds no restriction. Write the first column as . The required column sum forces the second column, giving Every member gives both required outputs; every compatible matrix has this form.
Step 4: Classify inversion and the missing information. The determinant is . Thus exactly the members with are invertible. If another input is outside the line through , those two inputs form a basis. Each standard coordinate vector has a unique expression in that basis, so the two measured images uniquely determine both columns. Any assigned image for this independent input defines one linear map; invertibility would additionally require independent output images.