Question 6
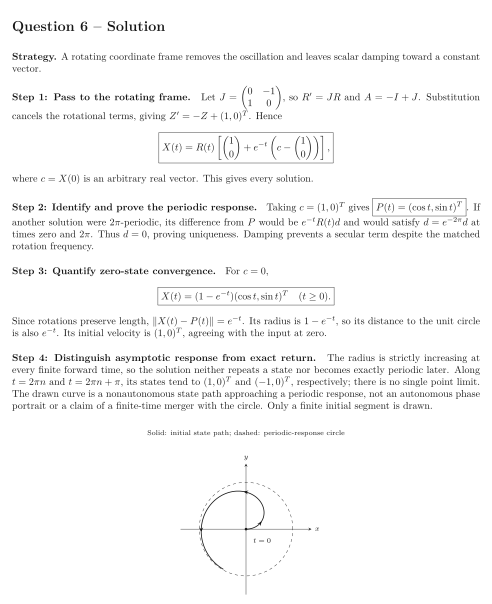
For , consider Investigate the response to a forcing that rotates at the homogeneous oscillation frequency.
Tasks
Use to derive and solve a constant-forcing equation for . Give the full family.
Find the unique -periodic solution and prove its uniqueness.
For , find the state, its distance from the periodic solution at the same time, and its distance from the unit circle.
Does the zero-state response become exactly periodic at a finite time or tend to a single point? Explain how its state curve should be interpreted in this time-dependent forced problem.
Show solutionHide solution
Question 6 – Solution
Strategy. A rotating coordinate frame removes the oscillation and leaves scalar damping toward a constant vector.
Step 1: Pass to the rotating frame. Let , so and . Substitution cancels the rotational terms, giving . Hence where is an arbitrary real vector. This gives every solution.
Step 2: Identify and prove the periodic response. Taking gives . If another solution were -periodic, its difference from would be and would satisfy at times zero and . Thus , proving uniqueness. Damping prevents a secular term despite the matched rotation frequency.
Step 3: Quantify zero-state convergence. For , Since rotations preserve length, . Its radius is , so its distance to the unit circle is also . Its initial velocity is , agreeing with the input at zero.
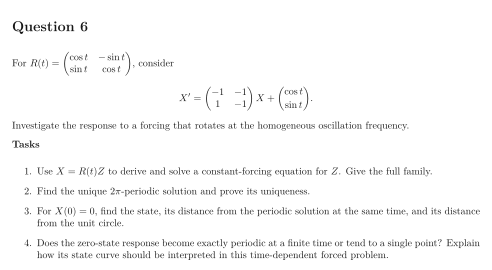
Step 4: Distinguish asymptotic response from exact return. The radius is strictly increasing at every finite forward time, so the solution neither repeats a state nor becomes exactly periodic later. Along and , its states tend to and , respectively; there is no single point limit. The drawn curve is a nonautonomous state path approaching a periodic response, not an autonomous phase portrait or a claim of a finite-time merger with the circle. Only a finite initial segment is drawn.
See the diagram in the original worksheet below.