Question 3
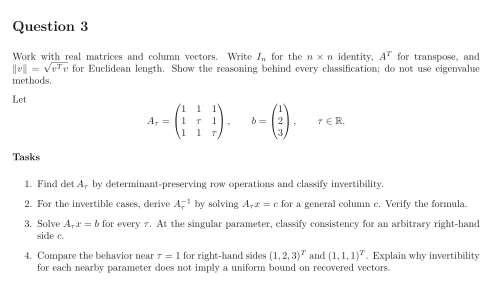
Work with real matrices and column vectors. Write for the identity, for transpose, and for Euclidean length. Show the reasoning behind every classification; do not use eigenvalue methods.
Let
Tasks
Find by determinant-preserving row operations and classify invertibility.
For the invertible cases, derive by solving for a general column . Verify the formula.
Solve for every . At the singular parameter, classify consistency for an arbitrary right-hand side .
Compare the behavior near for right-hand sides and . Explain why invertibility for each nearby parameter does not imply a uniform bound on recovered vectors.
Show solutionHide solution
Question 3 – Solution
Strategy. Subtracting the first row exposes the parameter that controls both inversion and the exceptional case.
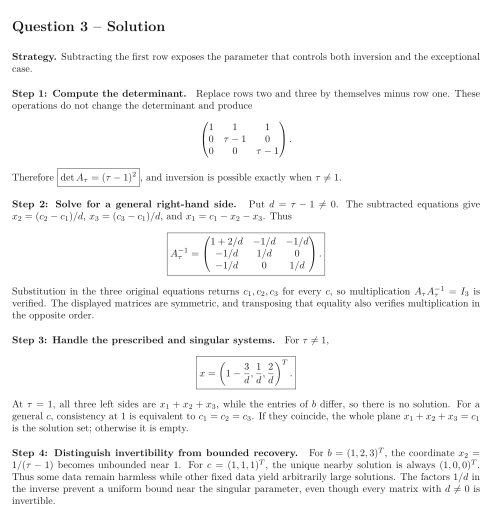
Step 1: Compute the determinant. Replace rows two and three by themselves minus row one. These operations do not change the determinant and produce Therefore , and inversion is possible exactly when .
Step 2: Solve for a general right-hand side. Put . The subtracted equations give , , and . Thus Substitution in the three original equations returns for every , so multiplication is verified. The displayed matrices are symmetric, and transposing that equality also verifies multiplication in the opposite order.
Step 3: Handle the prescribed and singular systems. For , At , all three left sides are , while the entries of differ, so there is no solution. For a general , consistency at is equivalent to . If they coincide, the whole plane is the solution set; otherwise it is empty.
Step 4: Distinguish invertibility from bounded recovery. For , the coordinate becomes unbounded near . For , the unique nearby solution is always . Thus some data remain harmless while other fixed data yield arbitrarily large solutions. The factors in the inverse prevent a uniform bound near the singular parameter, even though every matrix with is invertible.